
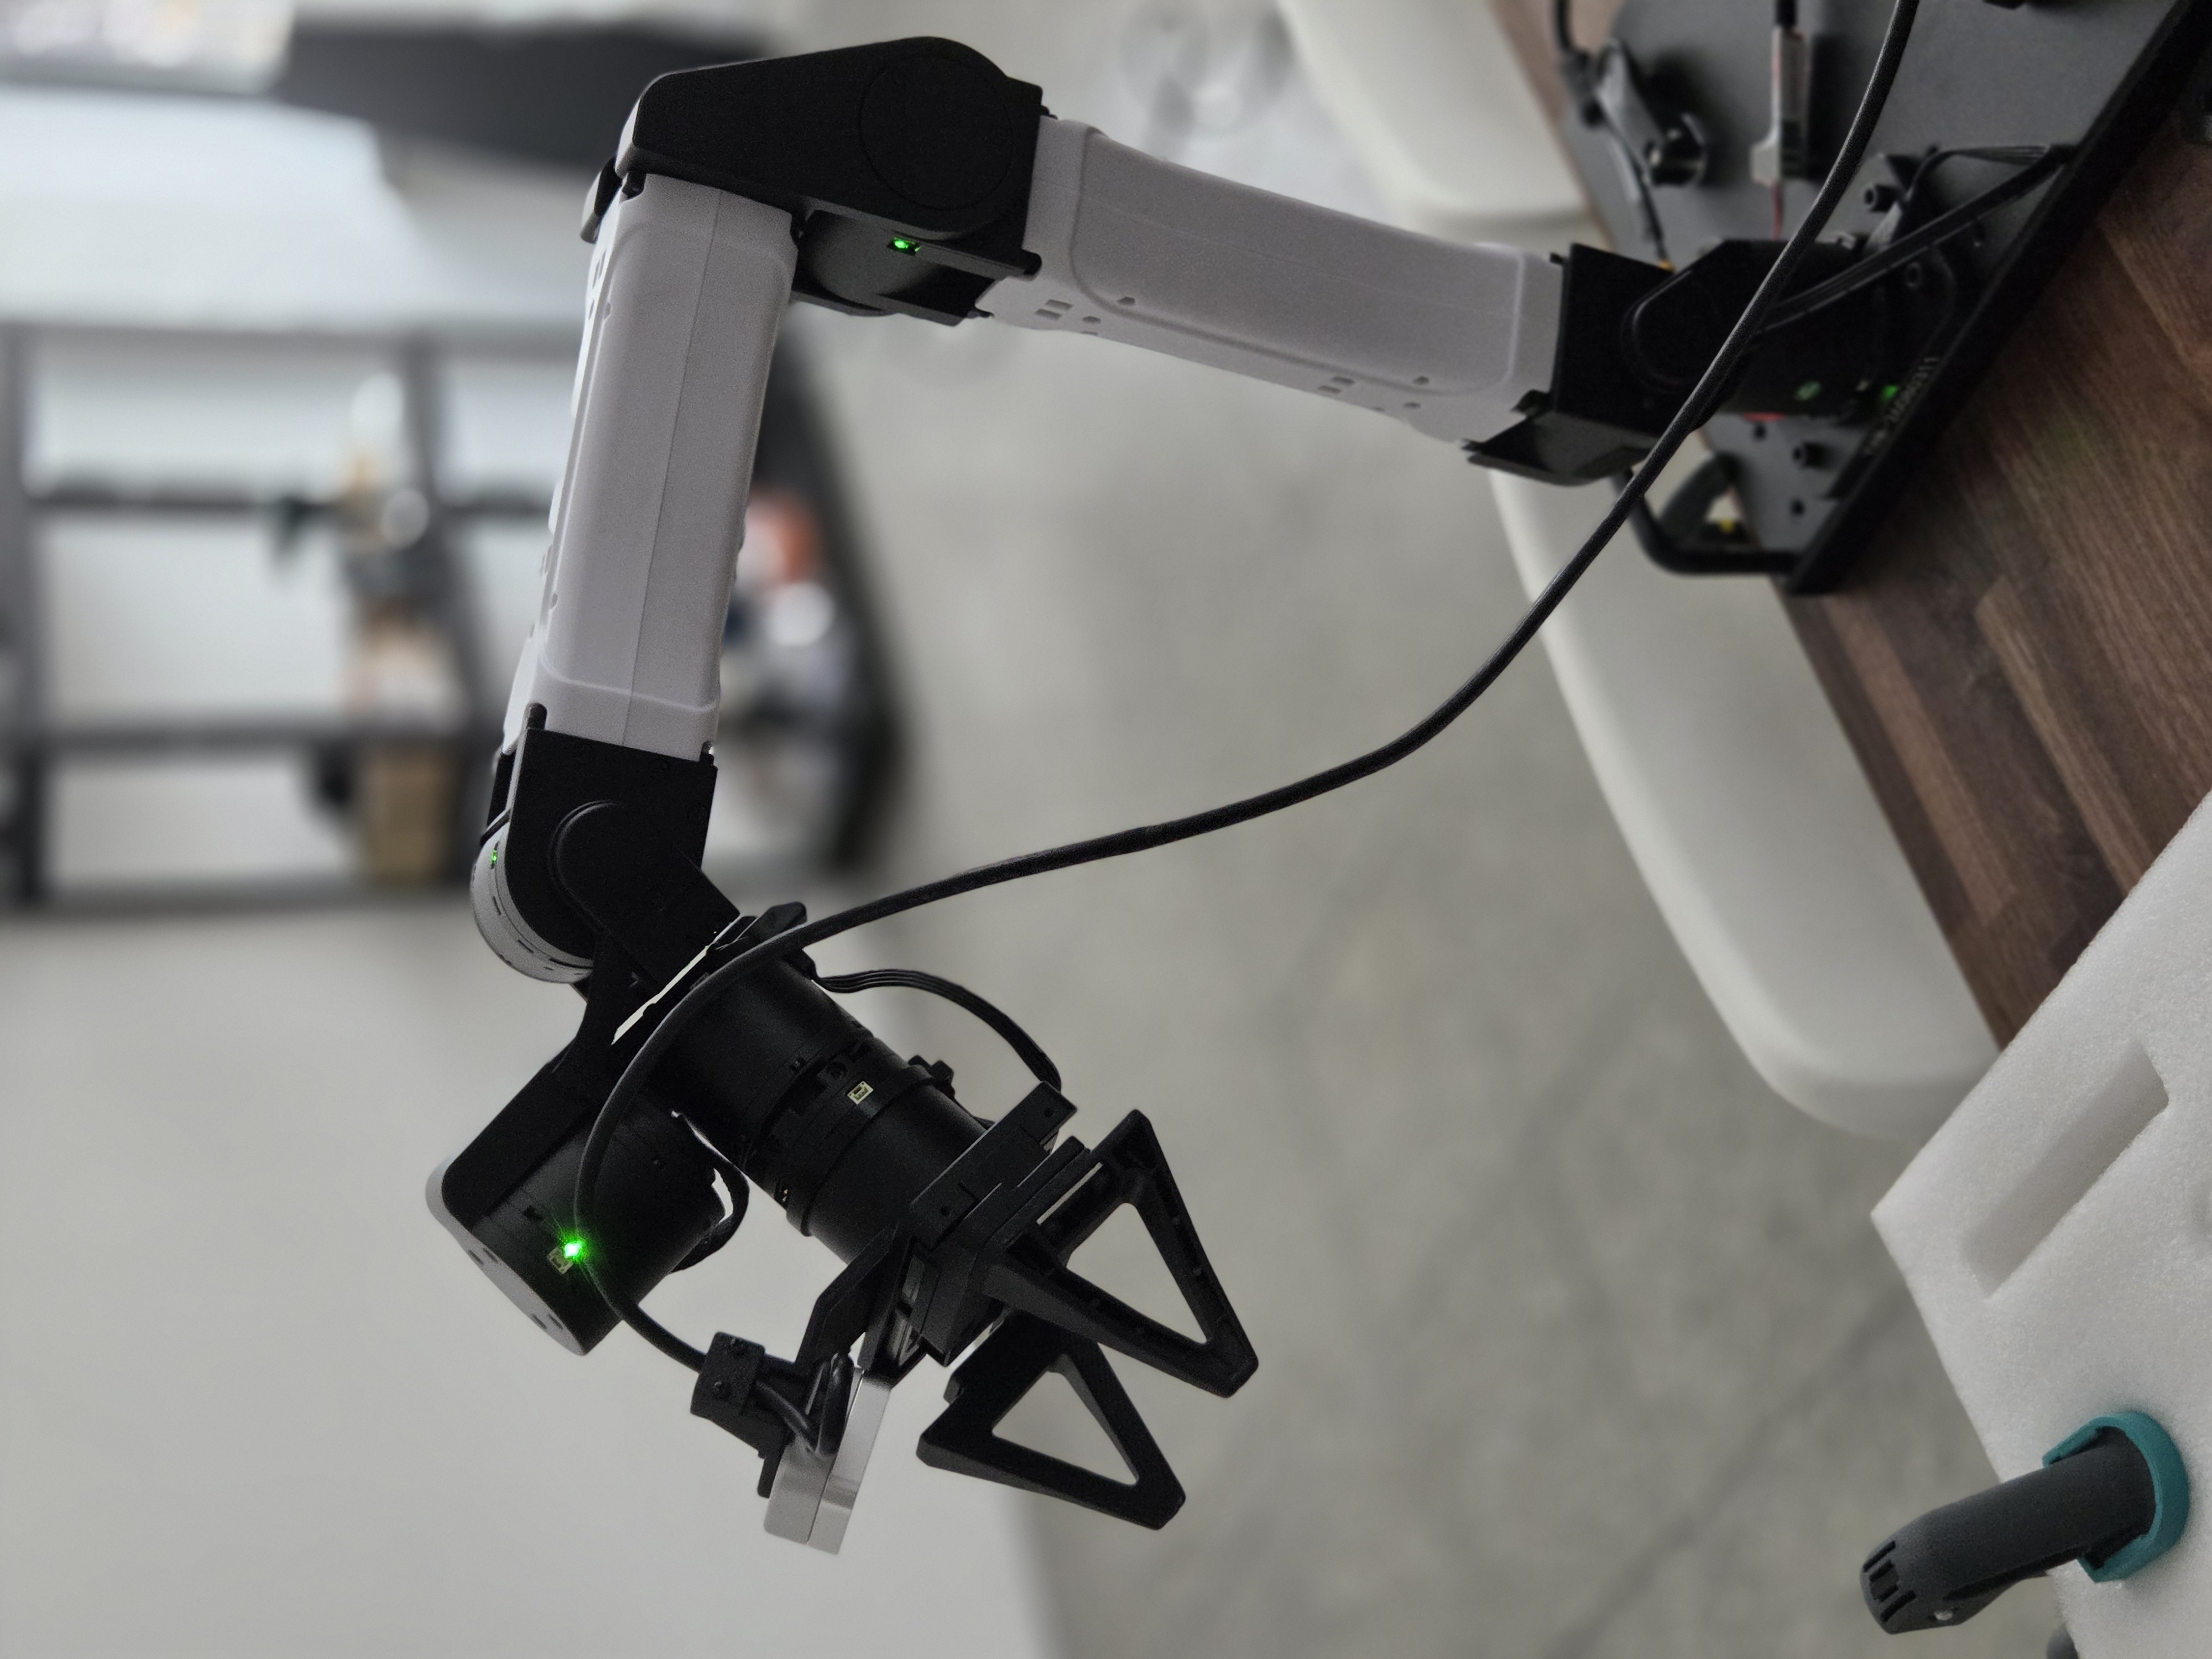
Vision-Language-Action models for robot manipulation tasks
16 Oct 2026 · 18:00–20:00
In this workshop, we’ll go through the full process of applying Vision-Language-Action models to robot manipulation tasks:
• setting up simulation and control for robot arms
• collecting demonstration data with a dual-arm teleoperation setup using the YAM Box
• fine-tuning a VLA model on the collected data
• running the trained models on the real robot
VLA fine-tuning can take too much time, so we likely won’t be able to train a model from start to finish during the workshop itself.
Instead, you’ll get hands-on experience with the surrounding workflow and become familiar with the main concepts, tools, and steps involved in collecting data, training, and deploying a VLA policy.